

Challenges
Maintaining Precision Across Complex Robotic Structures
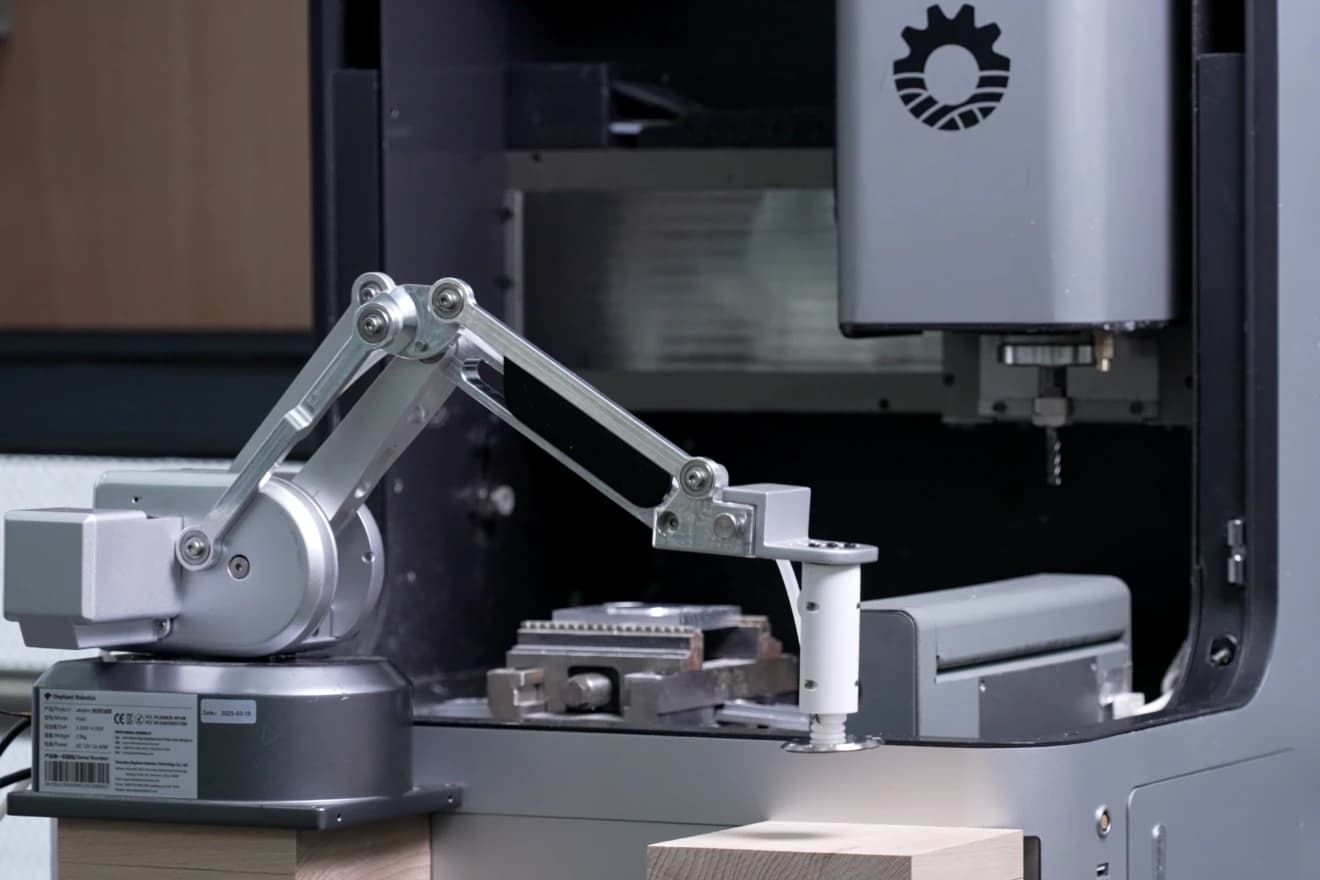
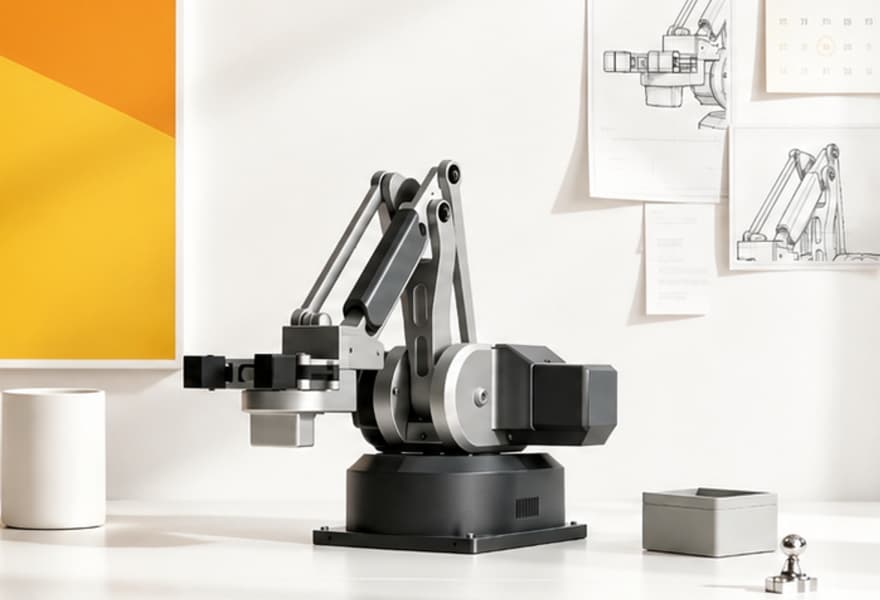
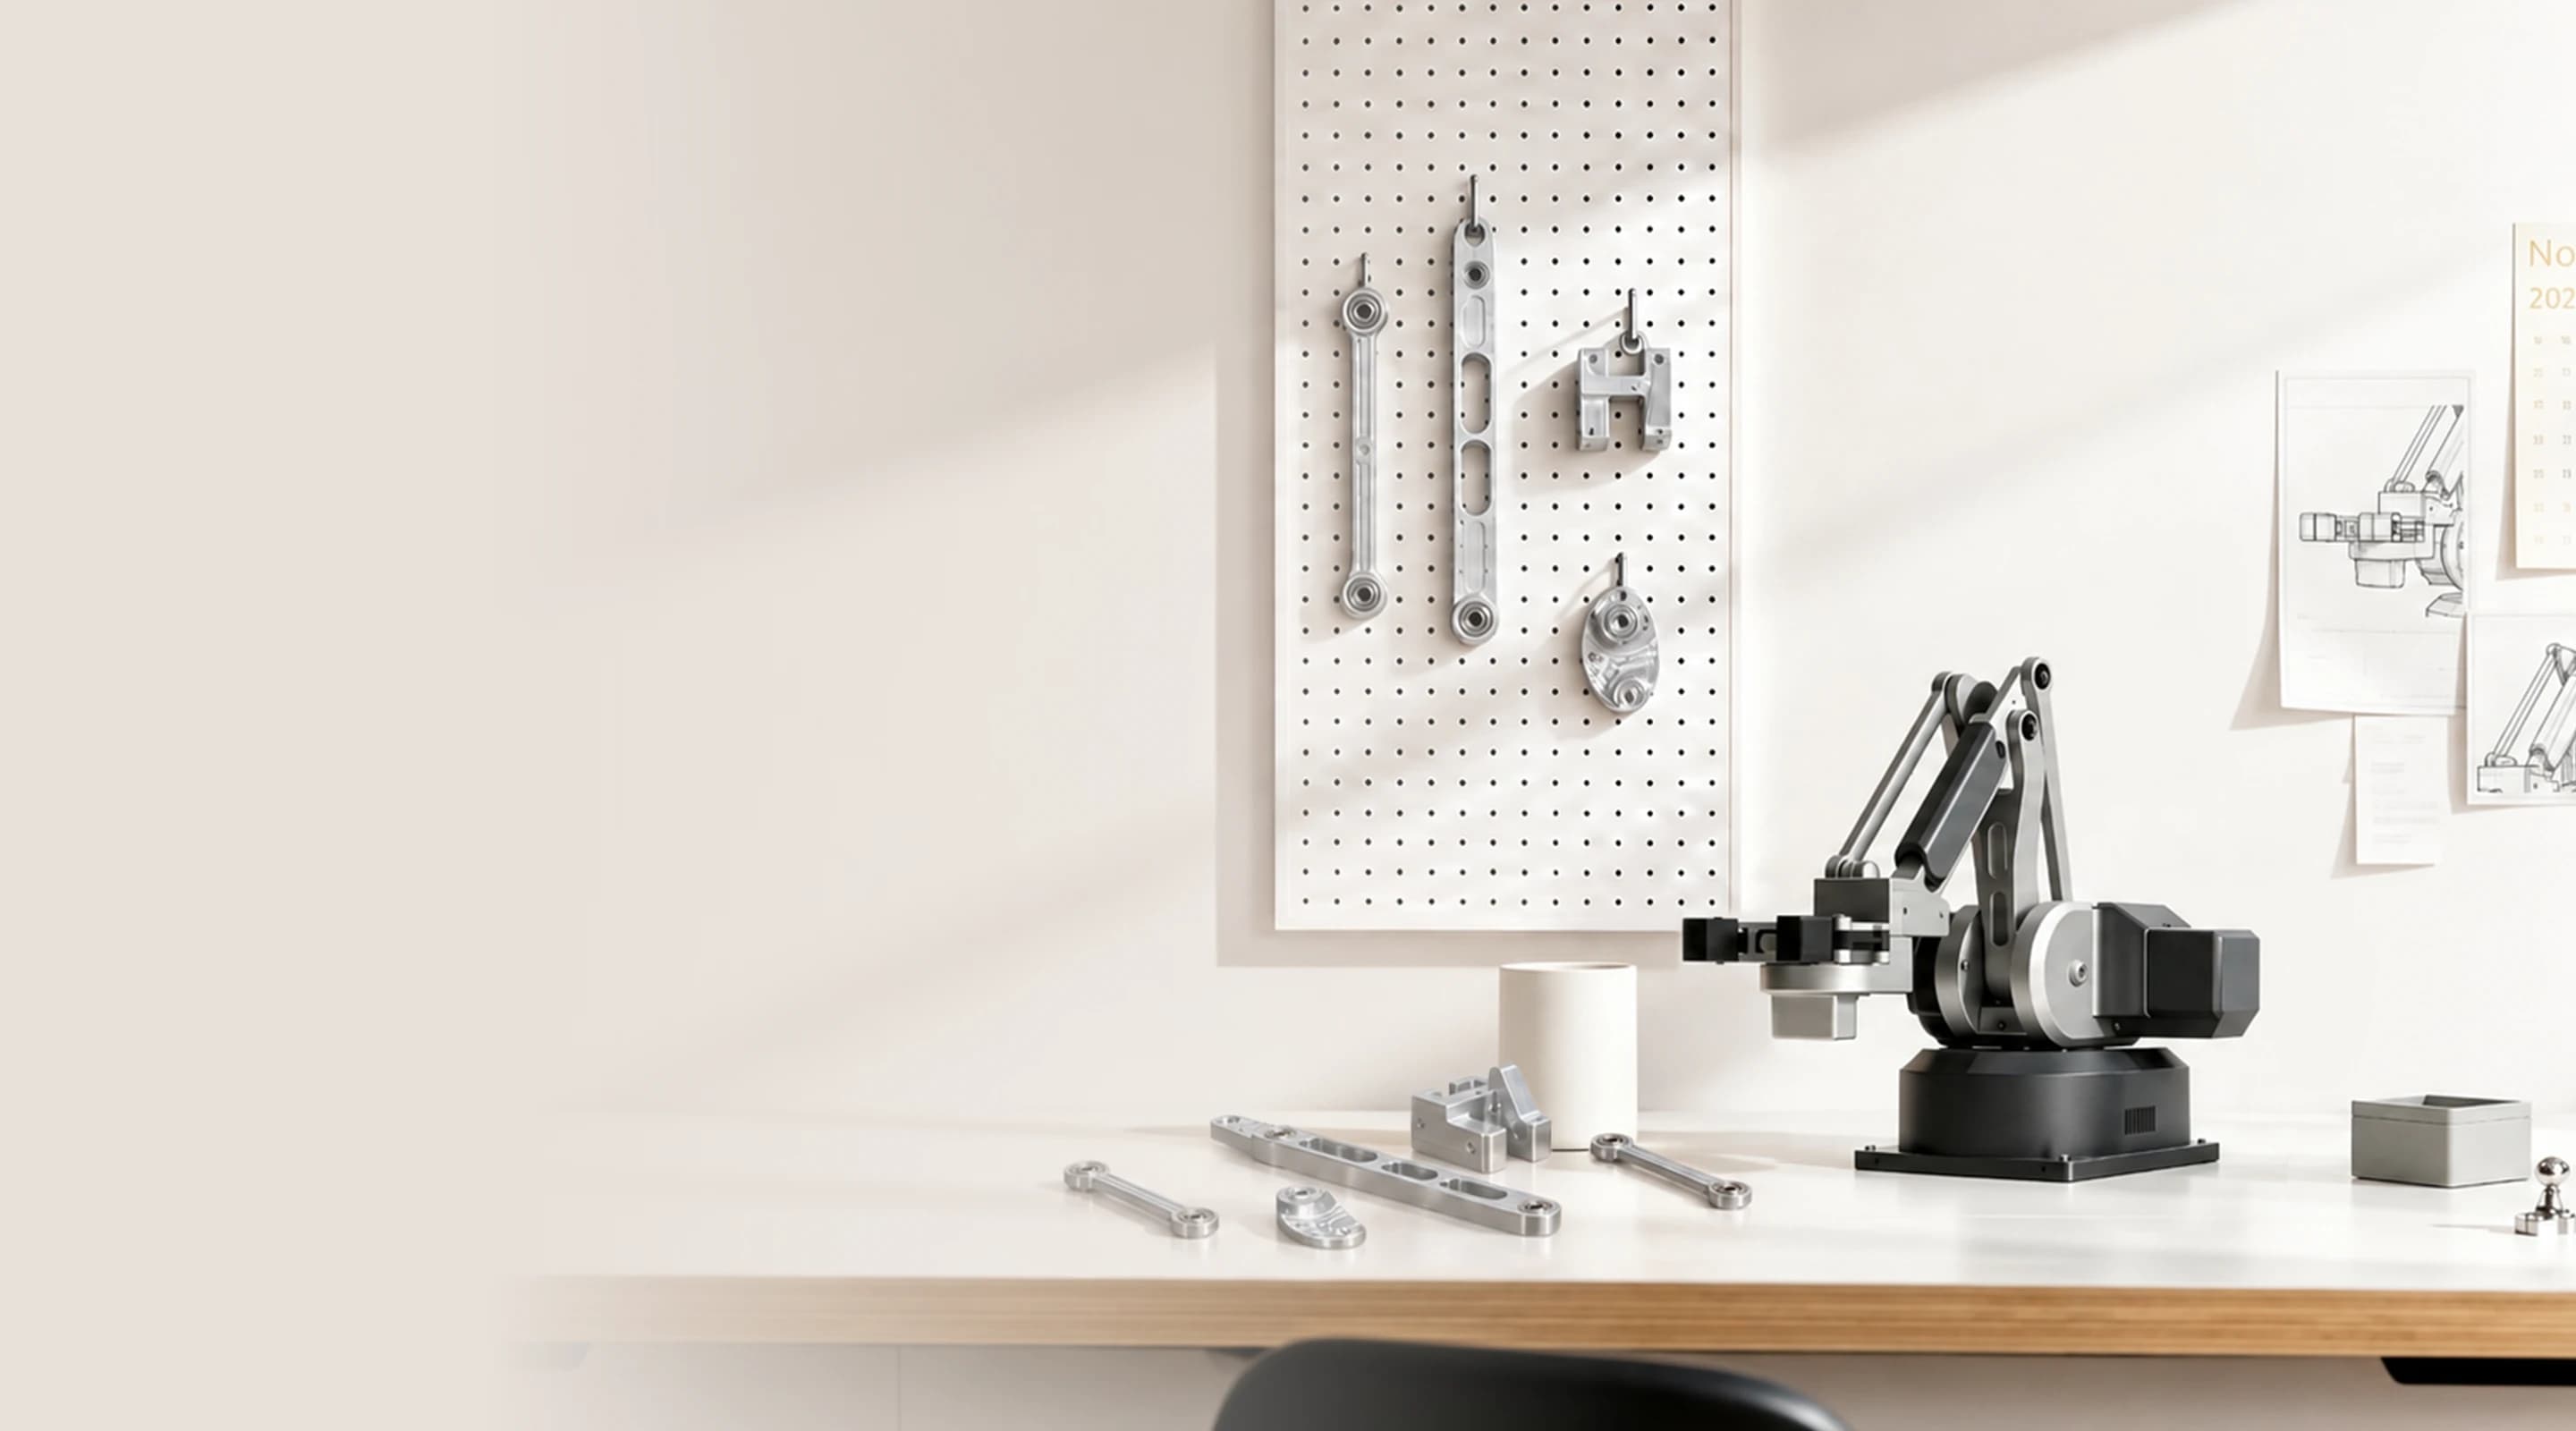
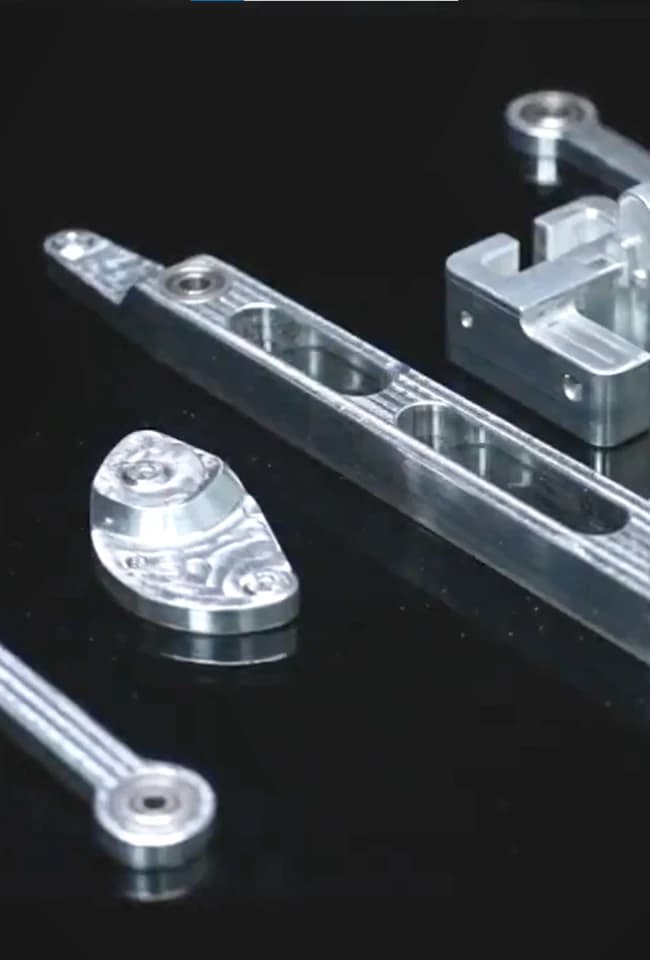
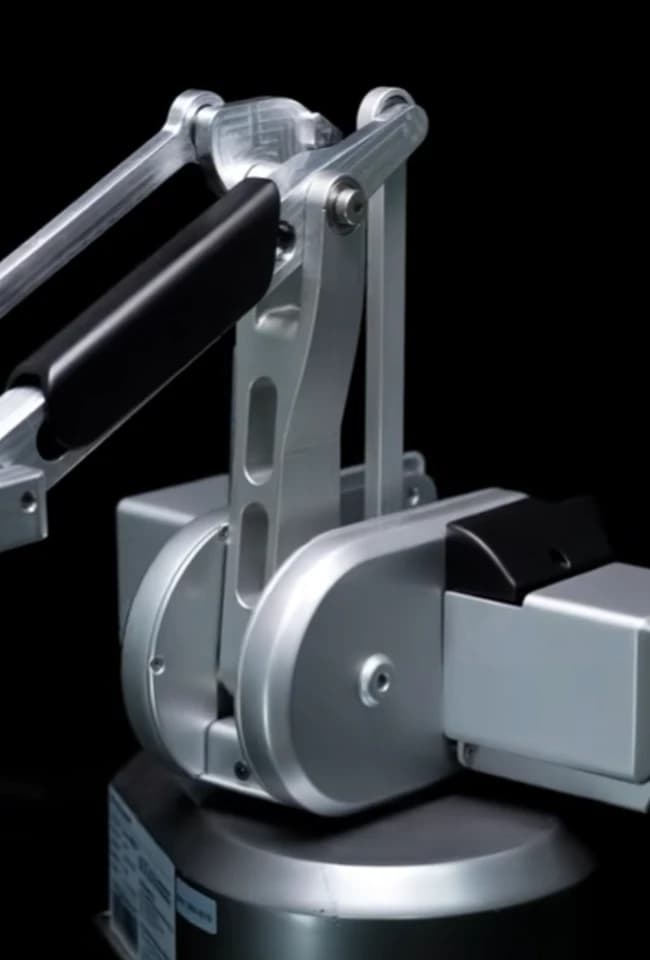
Unlike a single machined component, a robotic arm consists of multiple interconnected parts that must work together as a complete motion system.
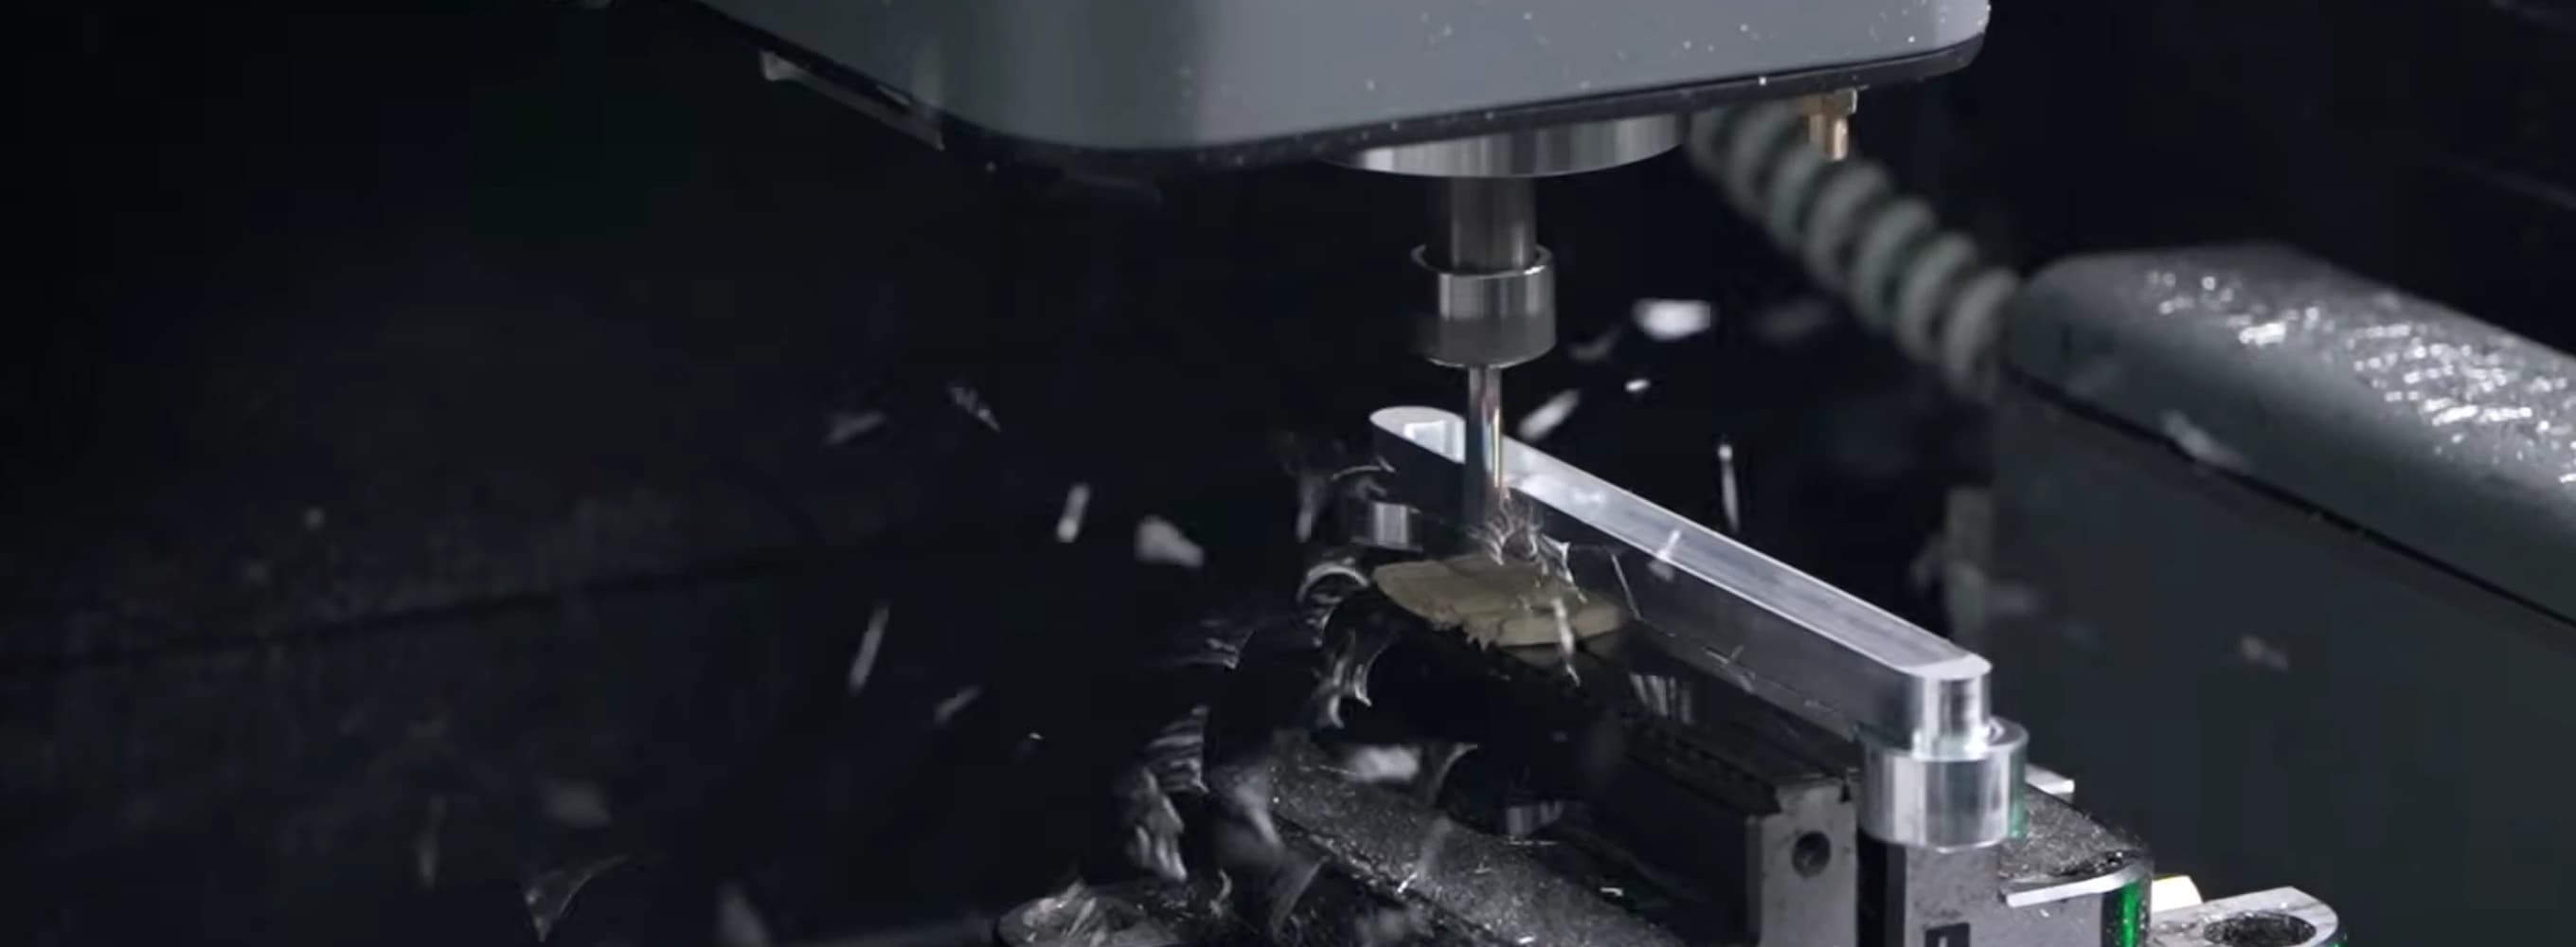
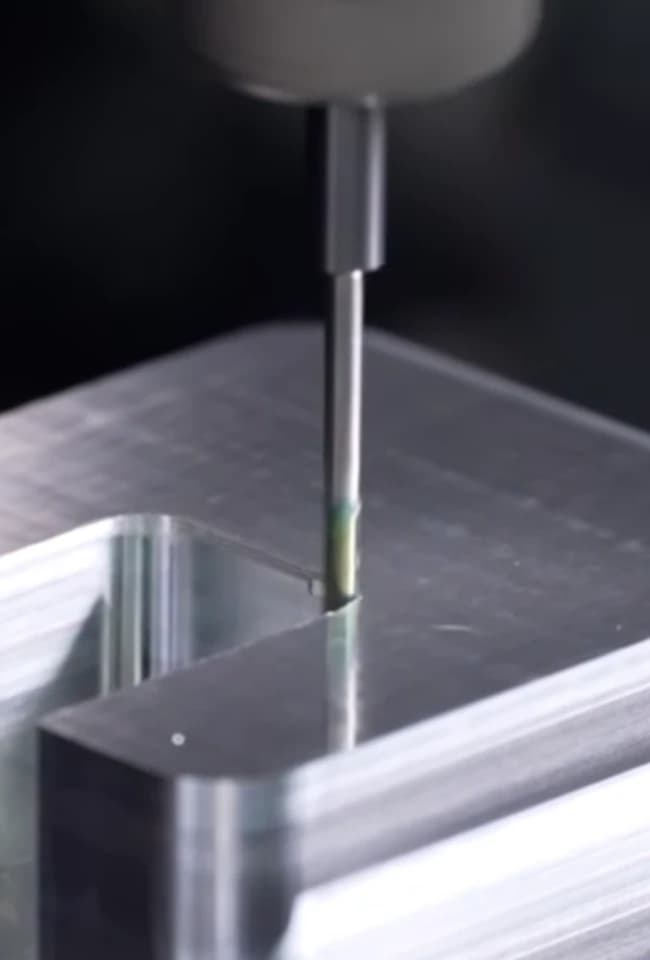
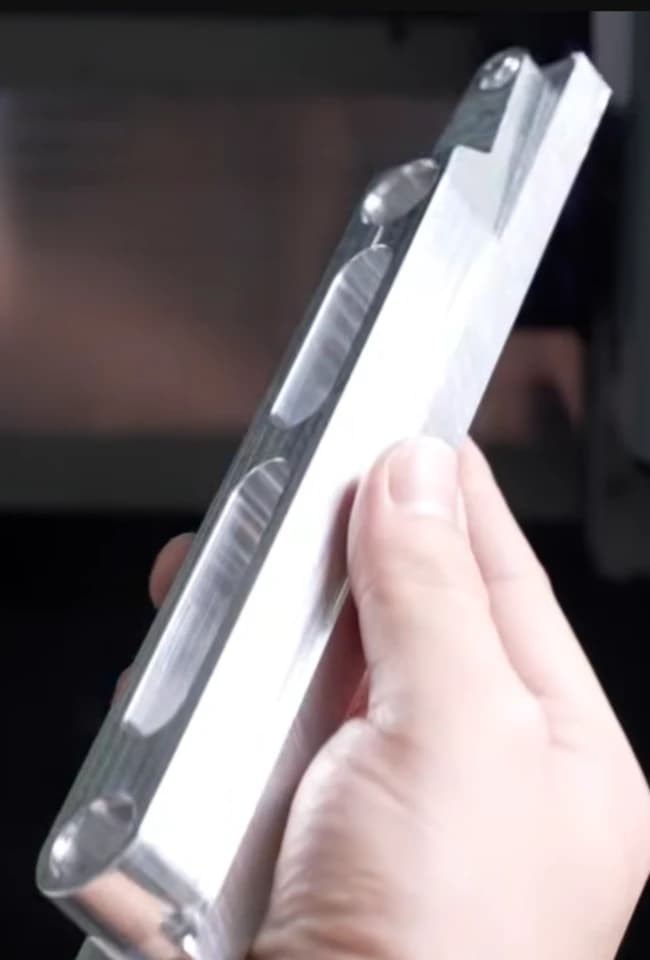
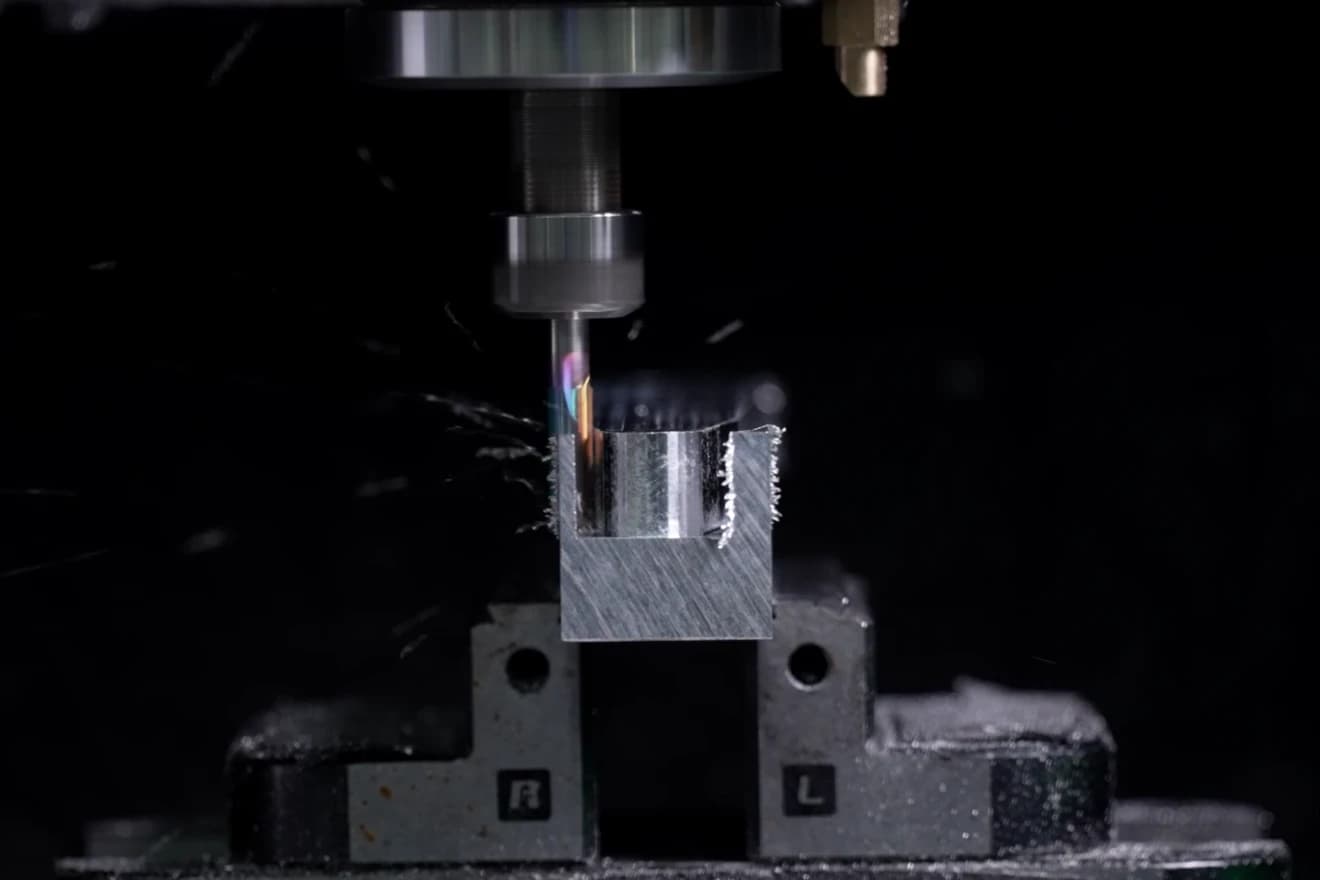
The project required consistent accuracy across different aluminum components, including multi-sided features, mounting surfaces, threaded holes, curved structures, and deep machining areas. Maintaining positional accuracy through multiple setups and ensuring every component could assemble correctly were the key engineering challenges.